Existing industrial facilities rarely match their original drawings perfectly. Over years of operation, facilities undergo equipment replacements, piping modifications, structural additions, capacity expansions, and other changes that may not always be reflected in available engineering documentation. This creates a challenge for teams planning brownfield modifications, retrofits, revamps, or expansion projects.
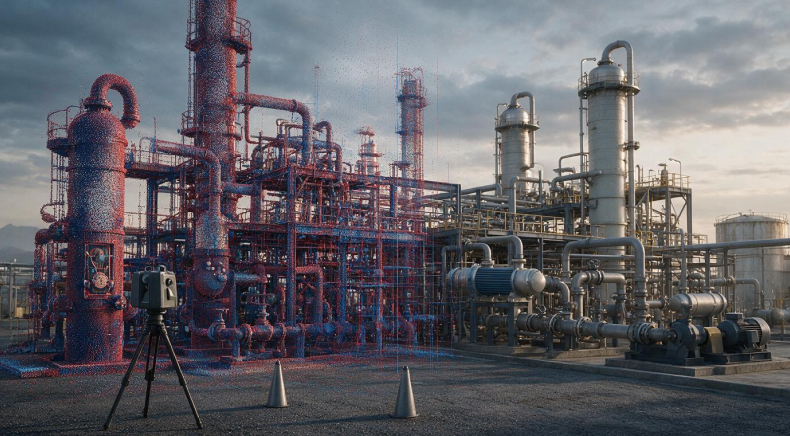
Point cloud-based 3D modeling helps address this challenge by creating a digital representation of actual site conditions. Using terrestrial laser scanning, LiDAR, photogrammetry, or other reality-capture technologies, engineering teams can capture millions of spatial data points representing existing structures, equipment, piping, and surrounding assets.
However, capturing a large volume of data does not automatically result in an accurate 3D model.
The accuracy of point cloud to 3D models depends on how effectively the data is captured, processed, interpreted, and validated. Factors such as scan resolution, registration, coordinate alignment, occlusions, noise, modeling methodology, and quality assurance can all influence the reliability of the final output.
For industrial engineering projects, this distinction is critical. An inaccurate model can result in incorrect piping routes, poorly positioned equipment, unexpected clashes, inaccurate tie-in locations, and costly site modifications. Conversely, a reliable model provides engineers with a better understanding of existing conditions before new design work begins.
In this blog, we explore what point cloud to 3D model accuracy means, the factors that influence it, methods used to verify model accuracy, the appropriate accuracy levels for different engineering applications, and the common causes of inaccurate models. We also examine why accuracy is particularly important for brownfield engineering and how Rishabh Pro Engineering approaches point cloud-based 3D modeling to support reliable engineering decisions.
What Does Point Cloud to 3D Model Accuracy Mean?
point cloud based 3d modeling accuracy refers to how closely the developed 3D model represents the physical objects and conditions captured at the site. A point cloud itself is a collection of spatial coordinates representing surfaces within a scanned environment. Depending on the technology used, the dataset may also include information such as color and reflectivity. The modeling process converts this raw spatial information into recognizable engineering objects such as pipes, equipment, structural members, platforms, and other plant components.
However, point cloud to 3D modeling accuracy is not simply about creating geometry that visually resembles the scanned facility. The model must maintain an acceptable level of geometric and positional consistency with the actual physical asset. For example, a pipe modeled several centimeters away from its actual location may appear visually acceptable when viewed from a distance. However, that same deviation could create problems when the model is used for a piping tie-in, spool design, equipment replacement, or clash detection exercise.
Therefore, accuracy must be evaluated according to the model’s intended purpose. A model developed for facility visualization may have different accuracy requirements than one developed for detailed engineering or construction planning. The objective is to ensure that the accuracy of 3D models created from point cloud is sufficient to support the engineering decisions for which the model will be used.
Key Factors Affecting Point Cloud to 3D Model Accuracy
Several factors influence point cloud based 3D modeling accuracy, beginning even before the first scan is performed.
Listed are some of the important factors;
- Scan Planning and Data Capture: The quality of the final model begins with the quality of the captured data. Scan positions, coverage requirements, accessibility, object complexity, and the level of detail required should be considered during scan planning. Insufficient scan coverage can result in missing geometry, while poorly positioned scans can create shadow areas around critical equipment, piping, and structural elements. Industrial facilities are particularly challenging because dense pipe racks, equipment, platforms, cable trays, and other objects can obstruct the scanner’s line of sight. A well-planned scan strategy helps capture critical interfaces from multiple positions and reduces the possibility of incomplete information.
- Scan Resolution and Point Density: Point density determines how much geometric information is available for model development. A dataset with insufficient density may make it difficult to identify smaller objects or accurately determine their dimensions. At the same time, excessively dense datasets can increase file sizes and processing requirements without necessarily improving engineering outcomes. The appropriate resolution should therefore depend on the required point cloud to 3D modeling accuracy and the intended use of the final model. High-detail capture may be particularly important around congested piping areas, equipment interfaces, structural connections, and proposed tie-in locations.
- Point Cloud Registration and Alignment: Large industrial facilities typically require multiple scans from different locations. These individual scans must be accurately aligned to create a unified point cloud. Registration errors can significantly affect the accuracy of 3D models created from point cloud. Even a small misalignment between scan positions can result in duplicated edges, distorted geometry, or incorrectly positioned components. The registration process should therefore be validated using appropriate reference points, overlap analysis, survey control, or other project-specific verification methods. Maintaining a consistent coordinate system is equally important when integrating the point cloud with existing drawings and engineering models.
- Noise and Data Quality: Raw point cloud data may contain noise, reflections, moving personnel, temporary equipment, or other unwanted objects. Reflective and complex industrial surfaces can further complicate the capture process. Data processing can help remove unnecessary information and improve the usability of the dataset. However, excessive filtering may remove valid geometry. The objective is to balance data cleanup with the preservation of critical engineering information.
- Occlusions and Missing Geometry: A scanner can only capture surfaces within its line of sight. As a result, objects positioned behind equipment, structural members, or dense piping may not be fully represented in the point cloud. These occlusions can create uncertainty during modeling. Critical missing areas should be identified early and addressed through additional scans, site photographs, field measurements, existing drawings, or engineering verification. Assumptions should be clearly identified rather than being presented as verified site conditions.
- Modeling Methodology and Engineering Interpretation: A point cloud does not automatically identify the engineering function of every object. While software and automated tools can assist with object recognition, industrial facilities often require experienced interpretation. A cylindrical cluster of points may represent a pipe, but determining its nominal size, routing, connection, and relationship with adjacent components requires additional engineering understanding. This makes multidisciplinary expertise an important contributor to point cloud-based 3D modeling accuracy.
How Is Point Cloud to 3D Model Accuracy Verified?
Developing the model is only one part of the process. The final output must also be validated against the available site data. One of the most common verification methods is to compare the developed 3D geometry directly against the source point cloud. This helps identify areas where the model deviates from the captured data.
The verification process may include:
- Point cloud-to-model comparison
- Dimensional measurement checks
- Cross-sectional analysis
- Alignment verification
- Comparison with survey control points
- Review using site photographs
- Field measurement validation
- Critical interface checks
- Clash and interference detection
Color-based deviation analysis can also help visualize differences between the model and the scanned environment. However, numerical deviation alone should not be the only measure of quality. Engineering teams should focus particular attention on critical components and interfaces. For example, an isolated structural element may have a different level of project risk than an equipment nozzle or piping tie-in that directly affects downstream design.
A structured QA/QC process should also document areas where scan data is incomplete or where assumptions were required. This provides greater transparency and helps engineering teams understand the confidence level associated with different parts of the model.
What Level of Accuracy Does a 3D Model Need?
There is no universal accuracy requirement for every point cloud-based 3D model. The required accuracy should be determined by the intended engineering application and the consequences of potential deviations.
For example, a model used for:
- Facility visualization may require moderate geometric accuracy.
- Space planning may require reliable overall dimensions and spatial relationships.
- Clash detection may require higher positional consistency.
- Brownfield piping modifications may require detailed verification around tie-in locations.
- Equipment replacement may require accurate interfaces, nozzle positions, and surrounding clearances.
- Fabrication and installation planning may demand a higher level of validation for critical components.
The most appropriate approach is to establish project-specific tolerances at the beginning of the project. Instead of asking, “What is the highest possible accuracy?”, engineering teams should ask, “What level of accuracy is necessary to support the decisions and deliverables required for this project?” This approach helps balance project cost, scanning effort, processing time, and engineering value.
It also prevents teams from applying the same modeling effort uniformly across an entire facility. High-risk or critical areas can receive greater attention, while less critical areas can be modeled according to their intended use.
Common Causes of Inaccurate Point Cloud-Based 3D Models
Inaccuracies can occur at multiple stages of the point cloud-to-model workflow.
- Incomplete Site Coverage: Insufficient scan positions can leave important areas hidden or partially captured. Modeling teams may then be forced to make assumptions about missing geometry.
- Poor Scan Registration: Incorrect alignment between individual scans can introduce positional deviations across the dataset. These errors can then be transferred into the 3D model.
- Low-Quality or Insufficient Data: Poor resolution, limited point density, excessive noise, or scanning under unsuitable site conditions can affect the ability to accurately interpret geometry.
- Incorrect Coordinate Systems: A correctly modeled object can still create coordination issues if it is positioned within an incorrect project coordinate system.
- Over-Reliance on Legacy Drawings: Existing drawings can provide useful reference information, but they may not reflect undocumented site modifications. Relying on them without comparing them against captured site conditions can introduce errors.
- Inadequate Engineering Interpretation: Automated modeling alone may not accurately identify every industrial component. Without appropriate engineering review, incorrect assumptions can be made about object types, sizes, connections, or functions.
- Insufficient Model Validation: Even high-quality scans can produce inaccurate models if the developed geometry is not systematically compared against the source data and critical measurements.
These issues demonstrate why point cloud to 3D model accuracy must be managed throughout the complete workflow rather than being checked only after modeling is complete.
Why Accuracy Matters in Brownfield Engineering
Accuracy becomes particularly important in brownfield engineering because new designs must work within an existing physical environment. Unlike greenfield projects, where engineering teams begin with a relatively clean design environment, brownfield projects require modifications to facilities that may have evolved over several years or decades. A small deviation in the representation of existing conditions can have significant downstream consequences.
For example, an inaccurately modeled pipe route can affect the available space for a new line. An incorrect equipment position can influence foundation modifications or connection design. Similarly, an inaccurate structural model can result in unexpected clashes during installation.
Reliable accuracy of point cloud to 3D models can therefore help engineering teams:
- Understand actual existing conditions
- Identify undocumented modifications
- Improve piping and equipment coordination
- Reduce the risk of design clashes
- Plan tie-ins more effectively
- Improve constructability reviews
- Minimize unexpected field modifications
- Support better planning for shutdown and installation activities
For organizations managing complex industrial assets, a reliable digital representation can provide a stronger engineering foundation for making modification and expansion decisions.
How Rishabh Pro Engineering Supports Accurate Point Cloud to 3D Modeling
At Rishabh Pro Engineering, point cloud-based 3D modeling can be approached as an engineering-driven process rather than simply a geometric conversion exercise. The process begins with understanding how the model will be used. Whether the requirement involves brownfield modification, piping rerouting, structural engineering, equipment integration, modularization, or constructability review, the intended application helps define the appropriate data capture and modeling strategy.
The approach can include the following key stages:
- Defining Model Requirements: Project teams establish the intended model use, critical areas, required level of detail, coordinate requirements, and validation expectations.
- Reviewing Point Cloud Quality: The captured data is assessed for registration quality, completeness, density, noise, and potential gaps before detailed model development begins.
- Establishing a Coordinated Spatial Reference: Maintaining coordinate consistency helps ensure that the point cloud and developed models can integrate with other engineering disciplines and project deliverables.
- Applying Multidisciplinary Engineering Expertise: Industrial facilities involve interconnected piping, structural, mechanical, and process systems. Engineering interpretation helps convert captured geometry into meaningful, usable engineering objects.
- Prioritizing Critical Areas: Not every part of a facility carries the same engineering risk. Critical zones such as tie-ins, equipment interfaces, congested areas, and modification locations can receive focused validation.
- Performing Structured QA/QC: The developed model can be reviewed against the source point cloud, survey references, field information, and other available project data. This helps identify deviations before the model is used for downstream engineering activities. Through this approach, the focus remains on creating a model that is fit for purpose and capable of supporting reliable engineering decisions.
- Building Reliable Engineering Models from Point Cloud Data: Point cloud technology has made it possible to capture detailed information about existing industrial facilities and transform physical environments into usable digital assets. However, the quality of the final output depends on more than the amount of data collected.
The accuracy of point cloud to 3D models is influenced by every stage of the workflow, including scan planning, data capture, registration, noise management, modeling, engineering interpretation, coordinate alignment, and validation. For industrial and brownfield projects, the objective should not simply be to develop a visually impressive 3D representation. The model must accurately support the engineering activities it is intended to serve.
At Rishabh Pro Engineering, our point cloud to 3D model services combines structured modeling workflows, multidisciplinary engineering expertise, and focused QA/QC to create reliable digital representations of existing assets. This supports improved coordination for piping modifications, equipment integration, structural changes, clash detection, constructability reviews, and other brownfield engineering requirements.
Ultimately, effective point cloud to 3D modeling accuracy is about confidence. Confidence that the model represents existing conditions sufficiently for its intended purpose, confidence that critical interfaces have been validated, and confidence that engineering teams can make informed decisions before changes move from the digital environment to the physical site.
Real Life Case Study
Laser Scan to 3D Modeling of Topside FPSO Module
Client: A US-based multinational energy corporation required multidisciplinary engineering support for an FPSO gas plant project in West Africa. The project involved developing a reliable digital representation of the existing FPSO topside and Gas Metering Unit (GMU) area to support engineering design, analysis, and coordination activities. Rishabh Pro Engineering was engaged to perform laser scan to 3D modeling of the FPSO topside module, combining site data capture and point cloud-based modeling with multidisciplinary engineering deliverables.
Project Scope
- Comprehensive laser scanning of the FPSO topside and GMU area
- Laser scan verification and capture of existing site conditions
- Conversion of point cloud data into a detailed 3D model
- FPSO topside process module design and 3D modeling
- Piping and mechanical system design support
- Equipment location planning
- Material Take-Off (MTO) development
- Structural analysis and engineering assessment
- Civil, structural, electrical, and instrumentation engineering support
- Preparation of detailed engineering reports and documentation
Engineering Highlights:
- Captured existing FPSO topside and GMU area conditions through comprehensive laser scanning.
- Converted laser scan and point cloud data into a detailed 3D model representing the existing offshore facility.
- Used the 3D model to support design validation, coordination, and identification of potential clashes.
- Developed piping layouts, mechanical system designs, and equipment location plans based on captured site information.
- Performed structural integrity assessment and developed supporting civil and structural engineering deliverables.
- Integrated multidisciplinary engineering inputs across piping, mechanical, civil, structural, electrical, and instrumentation disciplines.
- Prepared MTOs and detailed engineering reports to support downstream project execution.
Business Outcomes
- Created a reliable digital representation of existing FPSO topside conditions to support engineering and design activities.
- Improved design accuracy by using laser scan data for validation of the existing physical environment.
- Supported multidisciplinary coordination through a common 3D engineering model.
- Helped identify potential design conflicts and improve constructability before downstream execution.
- Reduced dependence on incomplete legacy documentation and manual site measurements.
- Enabled a more integrated engineering workflow for the FPSO gas plant project.
Concluding Thoughts
The value of point cloud-based 3D modeling goes beyond creating a digital replica of an existing facility. Its real value lies in providing reliable site intelligence for engineering design, modifications, coordination, and execution. The accuracy of point cloud to 3D models depends on effective scan planning, sufficient data coverage, proper registration, noise management, coordinate consistency, engineering interpretation, and structured validation. Any gap in this workflow can affect model reliability and introduce downstream engineering risks.
For brownfield projects, where new designs must integrate with complex existing infrastructure, achieving the right level of accuracy is essential. Reliable models help teams understand actual site conditions, identify potential clashes, validate critical interfaces, and minimize unexpected field modifications. At Rishabh Pro Engineering, we combine laser scan and point cloud data with multidisciplinary engineering expertise and QA/QC practices to develop fit-for-purpose models. Ultimately, effective point cloud based 3D modeling accuracy means achieving the right accuracy where it matters most thus enabling confident engineering decisions.